Docket #: S25-193
Gecko-Inspired Adhesive Lasso for Orbital Debris Capture
Stanford researchers in the Biomimetics & Dexterous Manipulation Laboratory have developed the Gecko Lasso, a lightweight tethered adhesive system for non-destructively contacting, de-tumbling, and capturing rotating orbital debris.
Orbital debris in low Earth orbit poses a growing collision risk, threatening the viability of critical orbital zones. Existing active debris removal (ADR) approaches, including friction systems, robotic grippers, and nets, struggle with tumbling targets, require favorable grapple features, or scale poorly to large objects.
De-tumbling is a necessary precursor to safe capture, and the Gecko Lasso fills this gap. A small gecko-inspired adhesive patch, mounted on a compliant boom tip and connected to a tension-controlled tether, is gently brought into contact with the spinning target. As the target rotates, it wraps the tether around itself, building tether tension for controlled de-tumbling. The patch requires minimal preload force and no external power to maintain grip. Benchtop experiments demonstrated reliable attachment at surface speeds up to 1.3 m/s, exceeding the measured spin rates of known debris targets in low Earth orbit.
Gecko Lasso Demonstration
(Courtesy the Biomimetics & Dexterous Manipulation Laboratory)
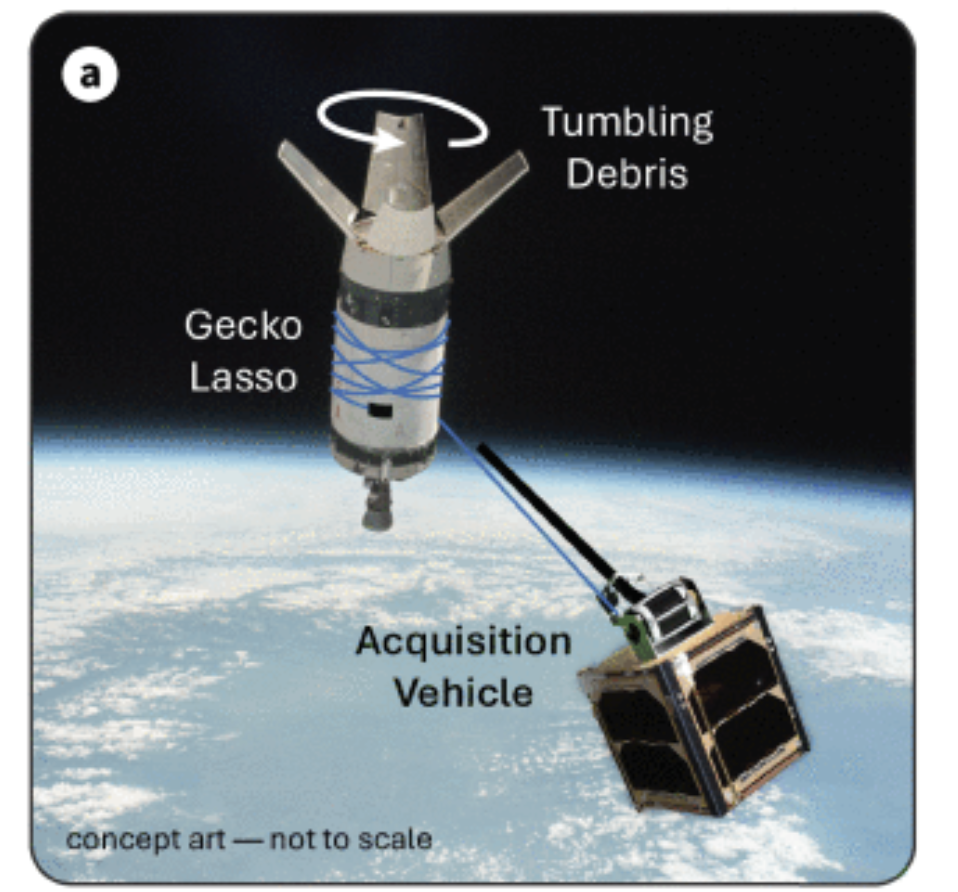
Figure 1 – Concept of tumbling debris capture by Gecko Lasso
(Image courtesy the Biomimetics & Dexterous Manipulation Laboratory)
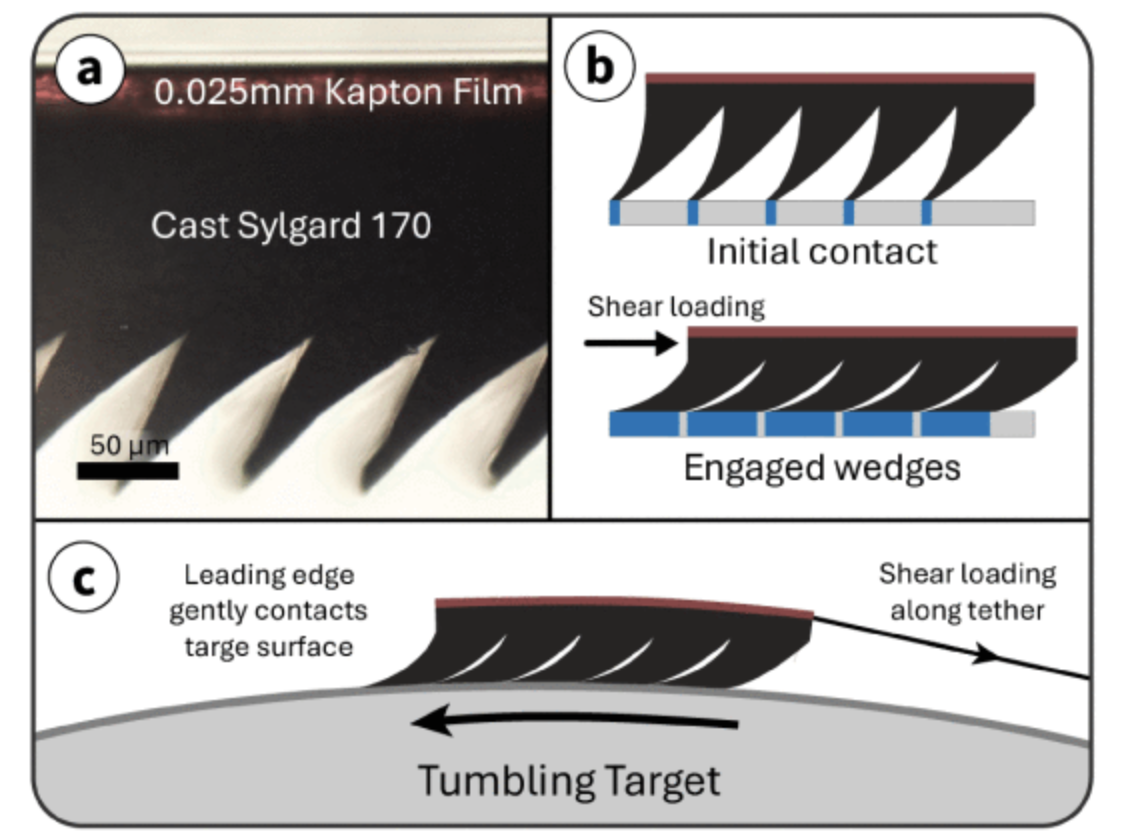
Figure 2 Gecko Lasso Anisotropic adhesive geometry (a), engagement details (b), and shear loading (c)
(Image courtesy the Biomimetics & Dexterous Manipulation Laboratory)
Stage of Development: Proof of Concept
Benchtop experiments validated reliable attachment to rotating metal targets at speeds up to 1.3 m/s.
Applications
- Active debris removal system targeting tumbling rocket bodies and defunct satellites
- Capture module for commercial space tug or debris acquisition vehicles
- Non-destructive grappling tool for on-orbit servicing and refurbishment missions
- Component recovery and recycling from decommissioned spacecraft
Advantages
- Gentle, low-preload contact minimizes disturbance to debris trajectory during initial engagement
- No external power required to engage or maintain adhesion
- Scales across a wide range of debris sizes and rotation rates
- Forms a mechanical tether connection without requiring grapple features on the target
Publications
- Rennich, E., Magruder, K., & Cutkosky, M. R. (2025). Gecko-Inspired Adhesive Lasso for De-tumbling Orbital Debris. International Conference on Space Robotics. doi: 10.1109/iSpaRo66239.2025.11436808.
Related Links
Similar Technologies
-
Micro-robots capable of towing 2000x its weight using dry adhesive S14-435Micro-robots capable of towing 2000x its weight using dry adhesive
-
Gripper device using shear-controlled dry adhesive film S14-443Gripper device using shear-controlled dry adhesive film
-
Distributed Sensor Networks Deployed by Soft Growing Robots S20-498Distributed Sensor Networks Deployed by Soft Growing Robots